TORCS
Overview
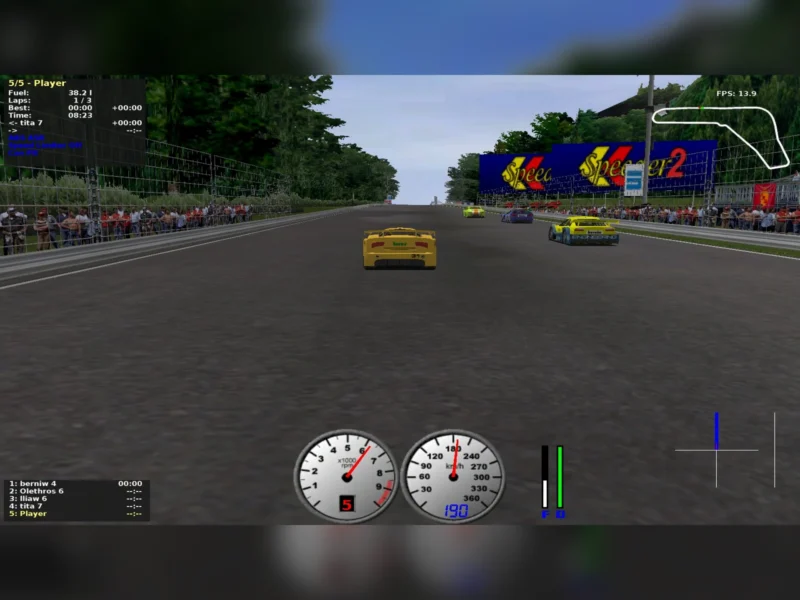
TORCS — The Open Racing Car Simulator — is a free, open-source 3D racing simulator for driving, developing artificial-intelligence drivers, and experimenting with vehicle simulation. Started in 2000 by Eric Espié and Christophe Guionneau and now maintained by Bernhard Wymann, it is unusual among free games in being both a playable racing title and a long-running research platform: its Robot Module Interface lets an AI driver read the simulation state and call back into steering, throttle, braking and gears.
Key Features
- 114 circuits — road, dirt, oval, experimental and test tracks ship with the simulator (TORCS 1.3.10 added 73 experimental tracks, two bridge test tracks and refreshed track maps).
- Robot Module Interface (AI drivers) — a documented C/C++ API gives custom drivers the full simulation state plus callbacks for steering, throttle, brake and gear selection.
- Headless batch racing — run repeatable races entirely from the command line, including custom race managers, for experiments and automated evaluation.
- Plug-in architecture — drivers, race management and simulation modules can each be replaced or adapted without patching the core.
- Realistic vehicle model — cars carry an engineering sheet (power, mass, drivetrain) and are simulated with tyre, suspension and drivetrain physics; the garage spans touring cars to purpose-built racers.
- Every common input device — keyboard, game pad, joystick or steering wheel; 1.3.10 raised human-player input updates to 250 Hz to cut input lag.
- Tunable graphics — MSAA anti-aliasing (4× by default) and anisotropic filtering (16× or the hardware maximum) are configurable in the display and OpenGL settings.
- Portable and light — Windows installer, plus Linux and FreeBSD built from a single all-in-one source archive; no DRM, no account, no store.
Why Use It
TORCS is one of the few free games that is genuinely useful outside gaming. Because the source ships with every release under the GPL and the driver interface is documented, it has been cited in peer-reviewed research from 2009 onwards — including the 2009 Simulated Car Racing Championship — and is widely used to teach control, vehicle dynamics and machine learning. At the same time it is a complete racing game: pick a car, pick one of the 114 tracks, and race against AI opponents. There is no advertising, no in-app purchase and no account requirement. The current stable release is 1.3.10 (1 October 2026), which also rewrote the Robot Tutorial for teaching.
Use Cases
- Racing against AI opponents on road, dirt and oval circuits with keyboard, pad or wheel.
- Building, training and benchmarking autonomous-racing agents (reinforcement learning, controller optimisation, imitation learning).
- University courses and student projects on vehicle dynamics, control theory and AI.
- Repeatable headless experiment batches with custom race managers and plug-in simulation modules.
- Tinkering: modding vehicles and tracks, or writing a robot driver in C/C++.
Platforms
Windows (official installer), Linux and FreeBSD (build from the all-in-one source archive: unpack, then ./configure && make, make install, make datainstall). Hardware-accelerated OpenGL plus FreeGLUT, PLIB, OpenAL, libpng/zlib and ogg/vorbis are required. Several Linux distributions package TORCS, but those packages can be old or stripped down.
Licence
Free and open source — the code, documentation and artwork are distributed under the GNU General Public License v2.0 (individual files state whether later versions are permitted); a few bundled third-party files use compatible permissive licences such as Expat/MIT.
Similar Tools
- Speed Dreams — free and open source, a TORCS fork with modernised graphics and physics.